Dexkit Phantom Fingers
Dexkit Phantom Fingers
- Carnegie Mellon University
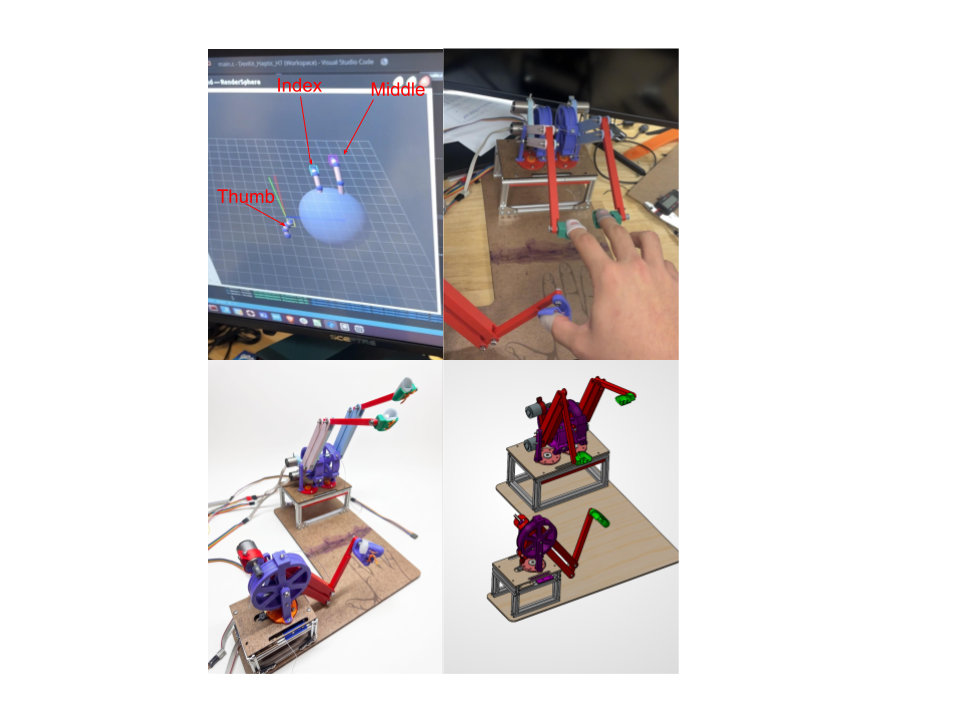
Abstract
Haptic teleoperation demands interfaces that faithfully reproduce human hand kinematics. Access to such interfaces is restricted by their price or their manufacturing requirements. We present Phantom Fingers (PFs), a 7 DoF haptic interface inspired by proven PHANTOM device principles, achieving high workspace alignment with human finger motion.
The system employs two independent Faulhaber DC, backdrivable motors per digit, driving capstan transmissions for the index and middle fingers. A third motor provides the thumb with natural opposition and out-of-plane rotation. We established link dimensions from anatomical data, this precision yields 96% human workspace coverage across all three digits. The system integrates into a modular assembly using aluminum extrusions and MDF frames, preserving both affordability and reproducibility. All mechanisms prioritize backdrivability and transparency, which are essential for stable force rendering during contact tasks. To test our interface we run a simulation environment where users can explore virtual objects placed in the PFs workspace, by solving the kinematics of our system we can provide stable kinesthetic haptic feedback under changes in the virtual object properties such as its stiffness and texture. Phantom Fingers demonstrates that careful biomechanical analysis and thoughtful transmission design can bridge the gap between intuitive operation and mechanical simplicity. The result is a platform well-suited for research, education, and real-world teleoperation scenarios. Future work includes the characterization of the device, and its use as a bilateral teleoperator.