Cellular mechanosensation controlling real-time robot decisions
Cellular mechanosensation controlling real-time robot decisions
- 1 Carnegie Mellon University
- 2 Harvard University
Abstract
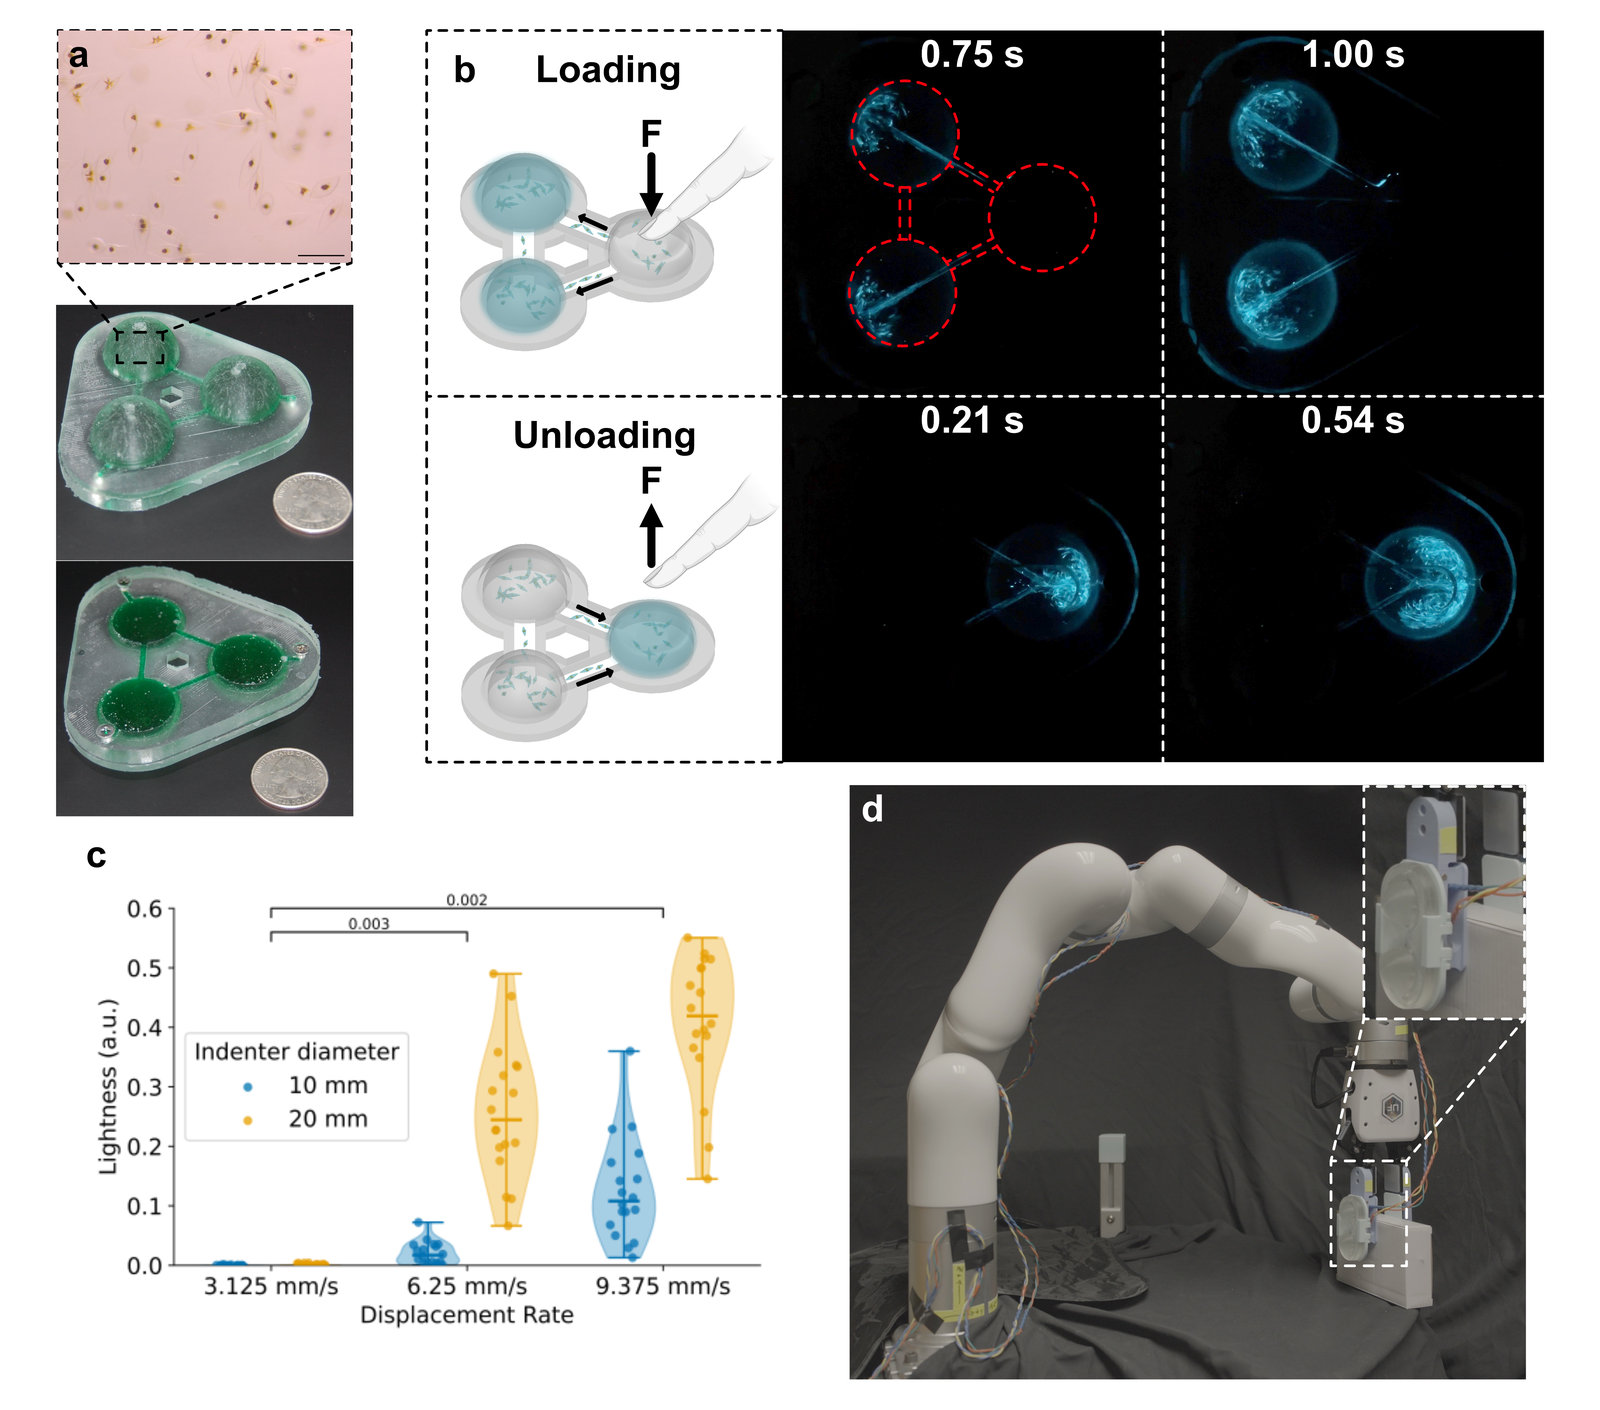
Living systems convert mechanical cues into decisions with speed and sensitivity that remain difficult to reproduce in robots. Here we report a biohybrid mechanosensor that uses mechanically responsive bioluminescent algae as an onboard feedback element for robotic decision making. The cells are enclosed in a soft hemispherical blister network that transforms external deformation into localized cellular light emission which are converted into real-time machine-readable outputs. The device geometry and excitation rate enable the sensor to distinguish mechanical events during loading and release. Integrated with a robotic gripper, the system directly controls manipulation decisions: arresting grip closure, detecting slip after grasp, and recognizing unplanned contact. This work establishes a route toward biohybrid sensors that couple evolved biological responsiveness to autonomous machines for decentralized decision making.